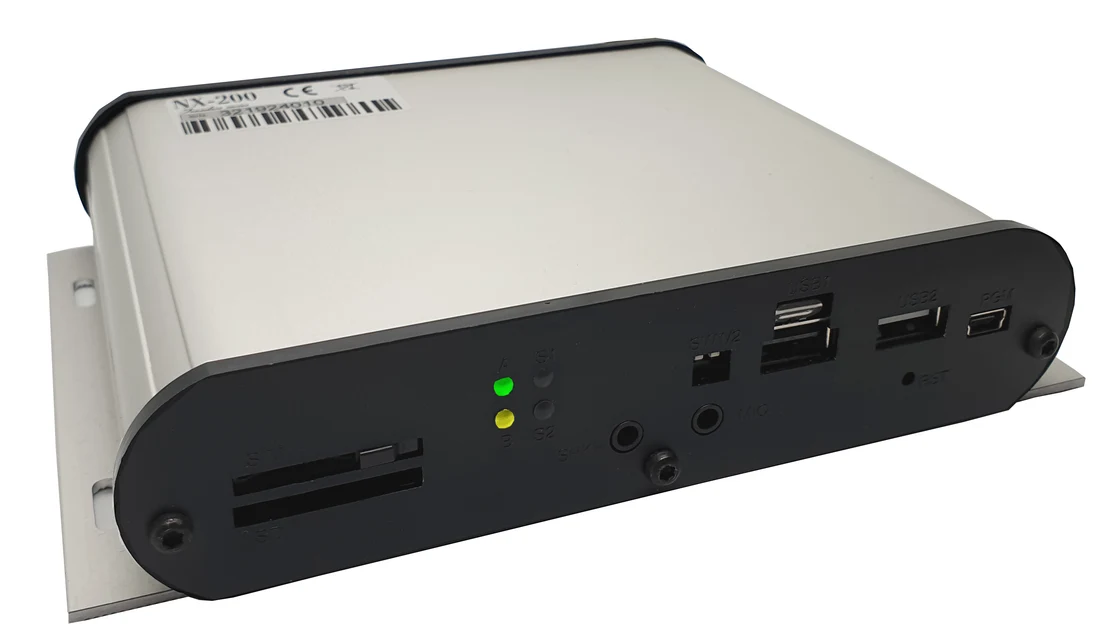
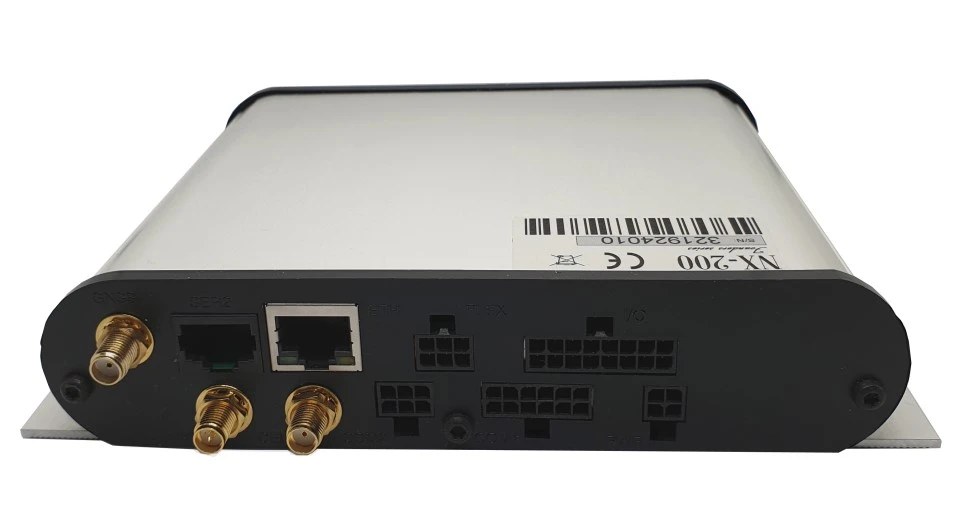
Work with vehicle interfaces
Two CAN 2.0B controllers, Ethernet, dual RS232, RS485 and 1-Wire connect the NX-200 to vehicle and peripheral systems. Expand I/O with standard Modbus modules.
Connect to the vehicle.
Build on the platform.
A programmable automotive M2M/IIoT gateway combining dual CAN, motion sensing, cellular connectivity and physical I/O with the NX32L execution architecture.
Connect vehicle and field interfaces to programmable application logic. The NX-200 brings communications, I/O and motion sensors together in an aluminium enclosure.
Two CAN 2.0B controllers, Ethernet, dual RS232, RS485 and 1-Wire connect the NX-200 to vehicle and peripheral systems. Expand I/O with standard Modbus modules.
Combine LTE Cat. 4, WLAN, Bluetooth Classic / Low Energy and multi-constellation GNSS. Choose the NX-200 DR variant when Automotive Dead Reckoning is required.
Motion sensors and an onboard Li-Ion battery support application power management. External-power loss powers the unit down by default; battery-operation behavior is configurable.
Positioning capabilities depend on the variant. Use the exact product identity when checking interfaces, documentation and installation requirements.
The standard model uses a multi-constellation GNSS receiver with GPS, GLONASS, Galileo and QZSS support.
The DR variant adds an Automotive Dead Reckoning GNSS receiver, with support for wheel-tick data or a physical wheel-tick input. Dead Reckoning is specific to this variant.
| Architecture | NX32L (NX32 for Linux) |
|---|---|
| Main processor | 32-bit ARM Cortex-A5, 500 MHz |
| RAM | 128 MByte LP-DDR |
| Flash memory | 512 MByte NAND; 16 MByte NOR |
| Persistent SRAM | 128 KByte with battery backup |
| Cellular | Worldwide LTE Cat. 4 |
|---|---|
| Wireless LAN | 2.4 GHz Wi-Fi |
| Bluetooth | Classic and Low Energy |
| Ethernet | 100 Mbps LAN |
| CAN | 2 × full CAN 2.0B controllers |
| Serial & peripheral interfaces | 2 × RS232, 1 × RS485, 1-Wire, 2 × USB host |
| USB service | Mini-USB service/programming port |
| Positioning | Multi-constellation GNSS; Automotive Dead Reckoning is specific to NX-200 DR |
| Digital inputs | 5, including the ignition input |
|---|---|
| Digital outputs | 4 high-side solid-state outputs |
| Flex inputs | 4; configurable analog/digital operation, 0–30 VDC |
| Analog inputs | 2; 0–10 VDC, up to 12-bit resolution |
| Motion sensors | 3-axis accelerometer, gyroscope and magnetometer |
| I/O expansion | Standard Modbus I/O modules |
| Removable storage | SD card and USB flash media |
| Supply voltage | 8–36 VDC |
|---|---|
| Internal battery | 2.6 Ah nominal Li-Ion |
| Enclosure | Aluminium profile with plastic parts; IP20 |
| Operating temperature | −40 to +65 °C; battery charging has separate limits |
| Dimensions | W 148 × H 34 × D 122 mm, excluding connectors and mounting flange |
| Weight | Approximately 500 g without accessories |
Choose the configuration for your installation and include the required region, interfaces and quantity in your enquiry.
Request a quote for this modelRemote M2M Studio access adds network connectivity and the RTCU Communication Hub. The Deployment Server is optional for managed remote updates.
Download the manufacturer data sheet, technical manual, mechanical drawings and conformity document. Match the document and unit variant before installation.
Software & firmware downloadsTalk through your vehicle interfaces, variant and development requirements with our team.